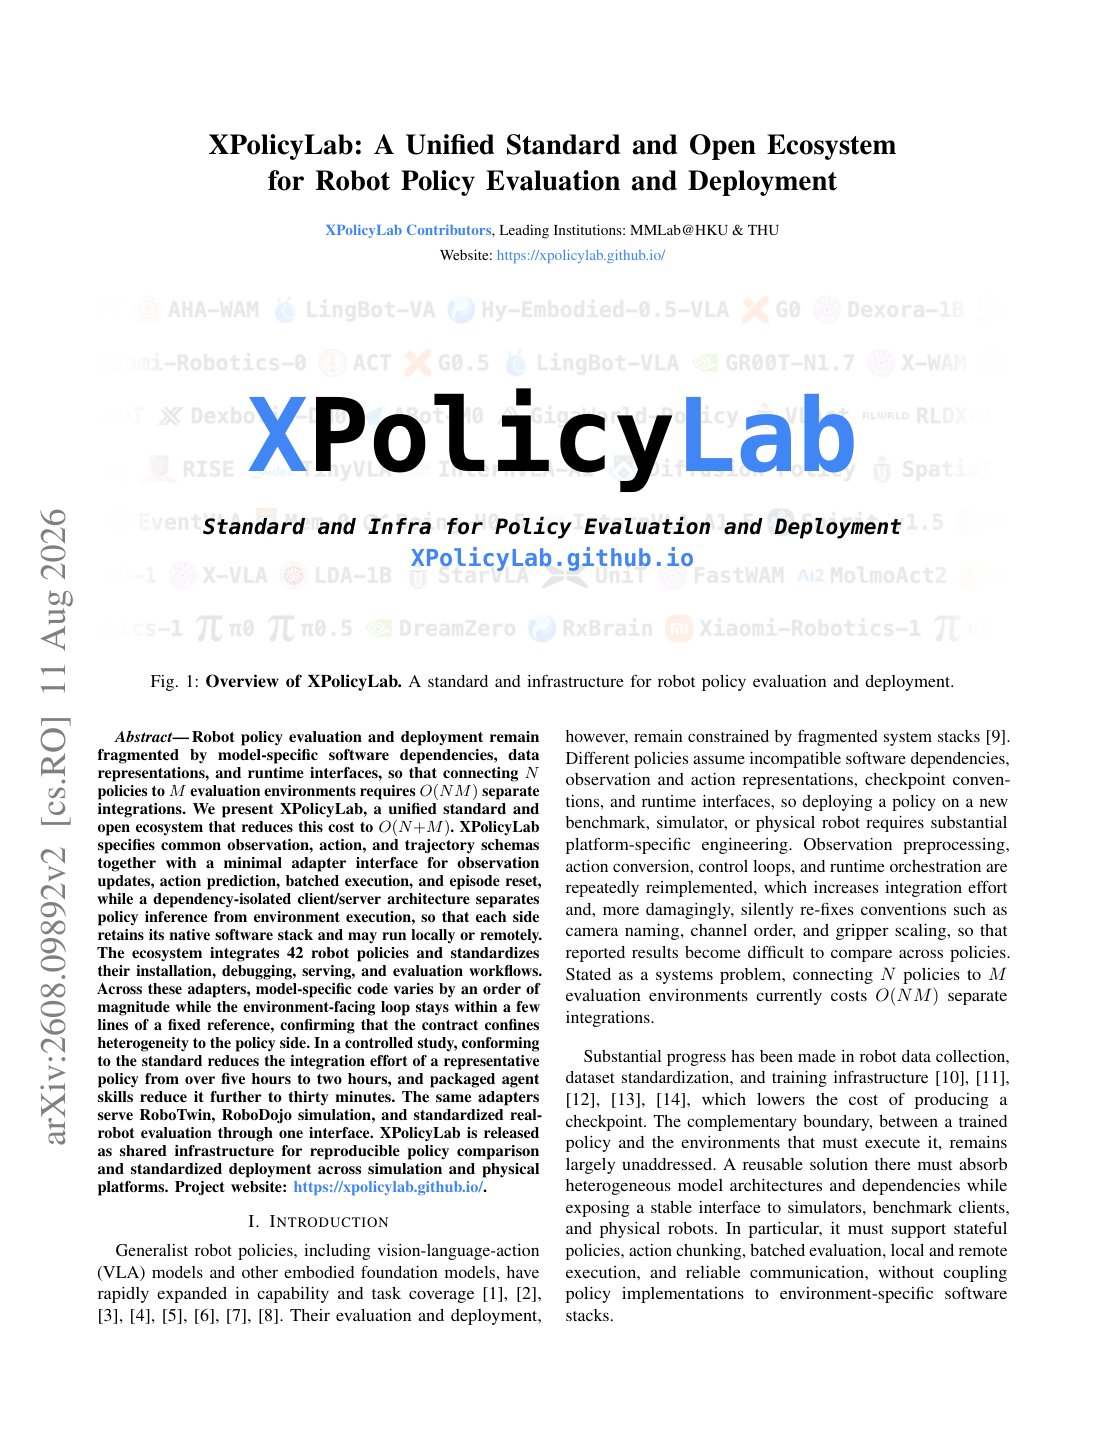
XPolicyLab Cuts Robot Policy Integration From NM to N Plus M
A shared policy contract and isolated client/server runtime let 42 robot policies connect to simulations and real-robot evaluation without pairwise adapters.
Aug 18, 20264 min2608.09892
2 articles on SOTA Papers
A shared policy contract and isolated client/server runtime let 42 robot policies connect to simulations and real-robot evaluation without pairwise adapters.
A two-stage VLA recipe combines 100K hours of UMI trajectories with cross-embodiment post-training, reaching 57.4% on RoboCasa365.